Plus Meta’s humanoid, QUAD hand, skilled tradespeople for robotics companies available, startup ideas from YC and more
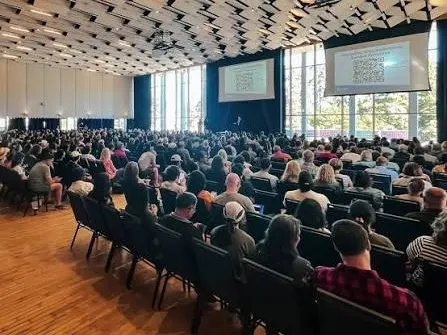
Forget RedBull, BARS, the Bay Area Robotics Symposium, is the quadruple espresso shot of the latest robotics/AI learning. The BARS format is jampacked with goodness. There were 29 faculty talks (5 minutes), 40 student talks (45 secs) and 13 industry talks (2 mins), and two short keynotes!
Many thanks to Negar Mehr, Mark Mueller and Monroe D. Kennedy III for organizing, with the help of students; Lasse Peters, Ryan Park, Kartik Nagpal, Dayi Dong, Seoyeon Choi and Marfred Barrera.
I now have a supersized reading list – pulling a few out here, from agentic world action models to Berkeley QUAD hand. In the industry talks, Ludo Robotics backed by Korean gaming giant Krafton announced their new agentic system for socially intelligent robots, integrating interactive speech, multimodal reasoning, memory, navigation and learned manipulation.
Ludi0.1: An Agentic System for Socially Intelligent Robots – Arxiv:2608.22035v1
A Quasi-Direct-Drive Underactuated Asymmetric Hand for Dexterous and Efficient Grasping and Manipulation arXiv:2609.27240 [pdf, ps, other]
Authors: Benjamin Davis, Chase Kidder, Hannah S. Stuart
Abstract: In this paper, we present the Berkeley QUAD (Quasi-direct-drive, Underactuated, Asymmetric Design) Hand, a four-finger anthropomorphic robotic hand with 11 degrees of freedom and 8 degrees of actuation. The design utilizes QDD actuation at the base of each finger, enabling high force transparency for dexterous, adaptive performance. However, the low torque density of these actuators traditionally presents major issues with size, weight, and thermal limits. We overcome this by applying bio-inspired asymmetry, delegating dexterity to the radial fingers through individual QDD actuation, and strength to the ulnar finger through an underactuated, compliantly coupled transmission driven by a larger QDD motor. A novel preloaded, linkage-based transmission permits this ulnar coupling in a way that preserves human-like workspace reachability. Under light loads, the ulnar motor drives the third (middle) finger directly for dexterity while the fourth (ring) finger mirrors its motion. However, under larger loads, the middle finger complies while the motor drives the ring finger further downwards and inwards toward the center of the grasp to apply better closure forces. Hardware evaluations validate this architecture, demonstrating that the hand achieves 29 out of 33 Feix taxonomy grasps and exhibits backdrive forces as low as 50 g for delicate interactions. Additionally, the underactuated fourth finger improves grasp closure and provides the spatial efficiency necessary for larger actuation, yielding up to a 96-fold reduction in heat generation during sustained loading. Webpage: https://benudavis.github.io/berkeley-quadhand/
GaP: A Graph-as-Policy Multi-Agent Self-Learning Harness For Variational Automation Tasks arXiv:2607.05369 [pdf, ps, other]
Authors: Kaiyuan Chen, Shuangyu Xie, Letian Fu, Justin Yu, William Pacini, Sandeep Bajamahal, Hudson Kim, Jaimyn Drake, Daehwa Kim, Haoru Xue, Jonathan Francis, Christian Juette, Peter Schaldenbrand, Muhammet Yunus Seker, Ruwan Wickramarachchi, Uksang Yoo, Guanzhi Wang, Adithyavairavan Murali, Balakumar Sundaralingam, S. Shankar Sastry, Yuke Zhu, Linxi “Jim” Fan, Spencer Huang, Ken Goldberg
Agentic World Action Models arXiv:2610.30136 [pdf, ps, other]
Authors: Zhuoyang Liu, Dantong Niu, Botong Zhang, Boning Shao, Jing Wang, Ruijie Zheng, Yuvan Sharma, Runyu Lu, Jiaming Liu, Renrui Zhang, Roei Herzig, Yutong Bai, Ken Goldberg, Danfei Xu, Yuke Zhu, Guanzhi Wang, Linxi “Jim” Fan, Trevor Darrell
RoboSimStudio: An Interactive Toolkit for Human and Agent Rapid Real2Sim of Robot Manipulation Tasks arXiv:2610.18835 [pdf, ps, other]
Authors: Kaiyuan Chen, Shuangyu Xie, Uksang Yoo, Xinyue Zhu, Cael Magner, Alvin Zhu, Daehwa Kim, Eric Heiden, Erwin Coumans, Miles Macklin, Spencer Huang, Ken Goldberg
ENPIRE: Agentic Robot Policy Self-Improvement in the Real World arXiv:2606.19980 [pdf, ps, other]
Authors: Wenli Xiao, Jia Xie, Tonghe Zhang, Haotian Lin, Letian “Max” Fu, Haoru Xue, Jalen Lu, Yi Yang, Cunxi Dai, Zi Wang, Jimmy Wu, Guanzhi Wang, S. Shankar Sastry, Ken Goldberg, Linxi “Jim” Fan, Yuke Zhu, Guanya Shi
The ground is shifting with advances in agentic AI being applied to robotics to introduce long context reasoning, explainability and validation. Also to create simulated objects and environments and much much more. CORL next week should be a total blast.
However, the frameworks in which robotics research must fit make it very difficult to work on the sort of robotics we need for commercial deployments, ie. 8 hour continual operation performing tasks with high accuracy, robustness to perturbation, error recovery, safety around humans (idiots) and most importantly, integration into a whole work process, not simply single or disconnected tasks.
That aspect made the DARPA Robotics Challenge very challenging back in 2015, and it’s still challenging today. Everyone who has deployed robots knows what I’m talking about! Integrating into the workplace and getting to and from the task is part of the process and rarely included in the job metrics.
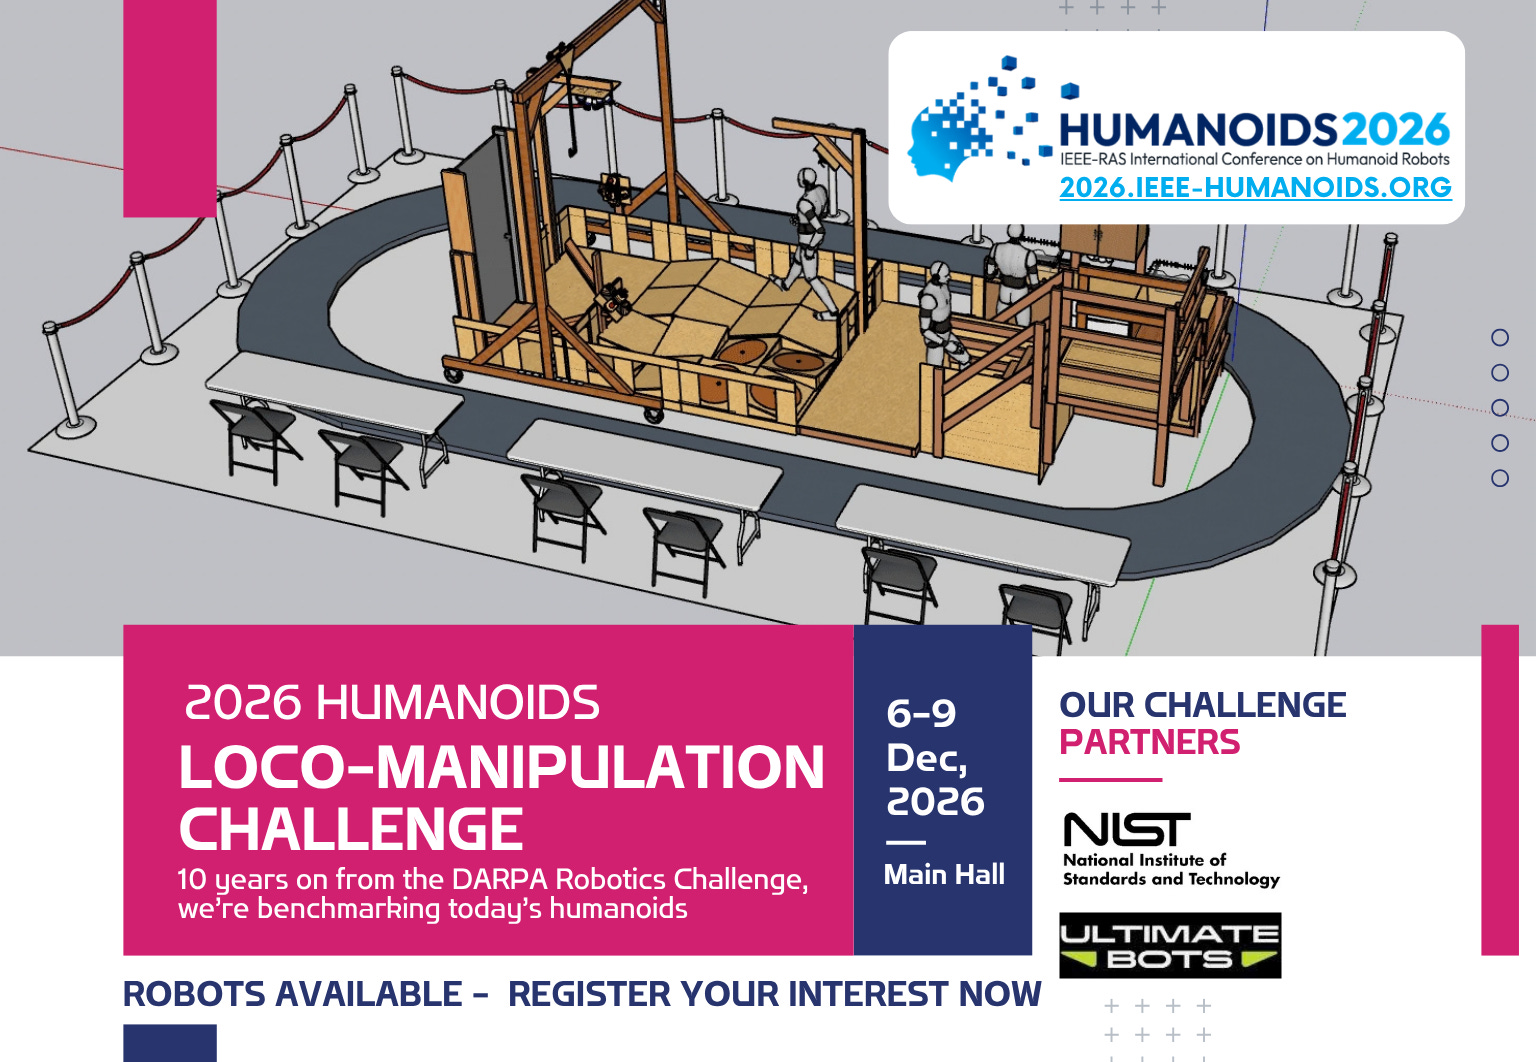
The new NIST Loco-Manipulation Challenge, launching at IEEE Humanoids 2026, is intended to pick up the DRC baton and benchmark how far robots have come since then. Registration of interest in being involved closes today. Robots are available thanks to Ultimate Bots.
If you enjoy Robots & Startups please restack. To receive new posts and support my work, consider becoming a free or paid subscriber.
Looking for skilled tradespeople?
If you are a robotics company looking for skilled tradespeople, the Association of Manufacturers Bay Area’s Workforce Development Board and the Bay Area Community Colleges can help.
Let us know what you’re looking for and we’ll pass it on.
Physical AI Frontier Night with Cybernetix Ventures and Matter Venture Partners
Great to have some East Coast robotics VCs joining us in the Bay Area for an evening of panels and high quality networking. First panel was “Beyond the Demo: Making Physical AI Work in the Real World” with Ross Diankov, Sam Lurye, Kahini Shah, and Brock Csira. Second panel was “Parts and Policy: Navigating The Robotics Supply Chain” with Ann Torres, Rajat Bhageria and Fady Saad.
Cybernetix Ventures portfolio companies include Verve Motion, Dash Bio, Corsha ,Cambrian Vision, Andromeda Surgical, Raise Robotics, Rugged Robotics and Airwork. Sam Abidi who is based in the Bay Area will be joining the Cybernetix team as a venture partner.
Matter Venture Partners has just closed their $450 million Fund 2 for early-stage HardTech startups across semiconductors, robotics and Physical AI, AI infrastructure, quantum computing, advanced manufacturing, energy building blocks, and AI for the advancement of science. Some portfolio companies include Path Robotics and Rhoda AI.
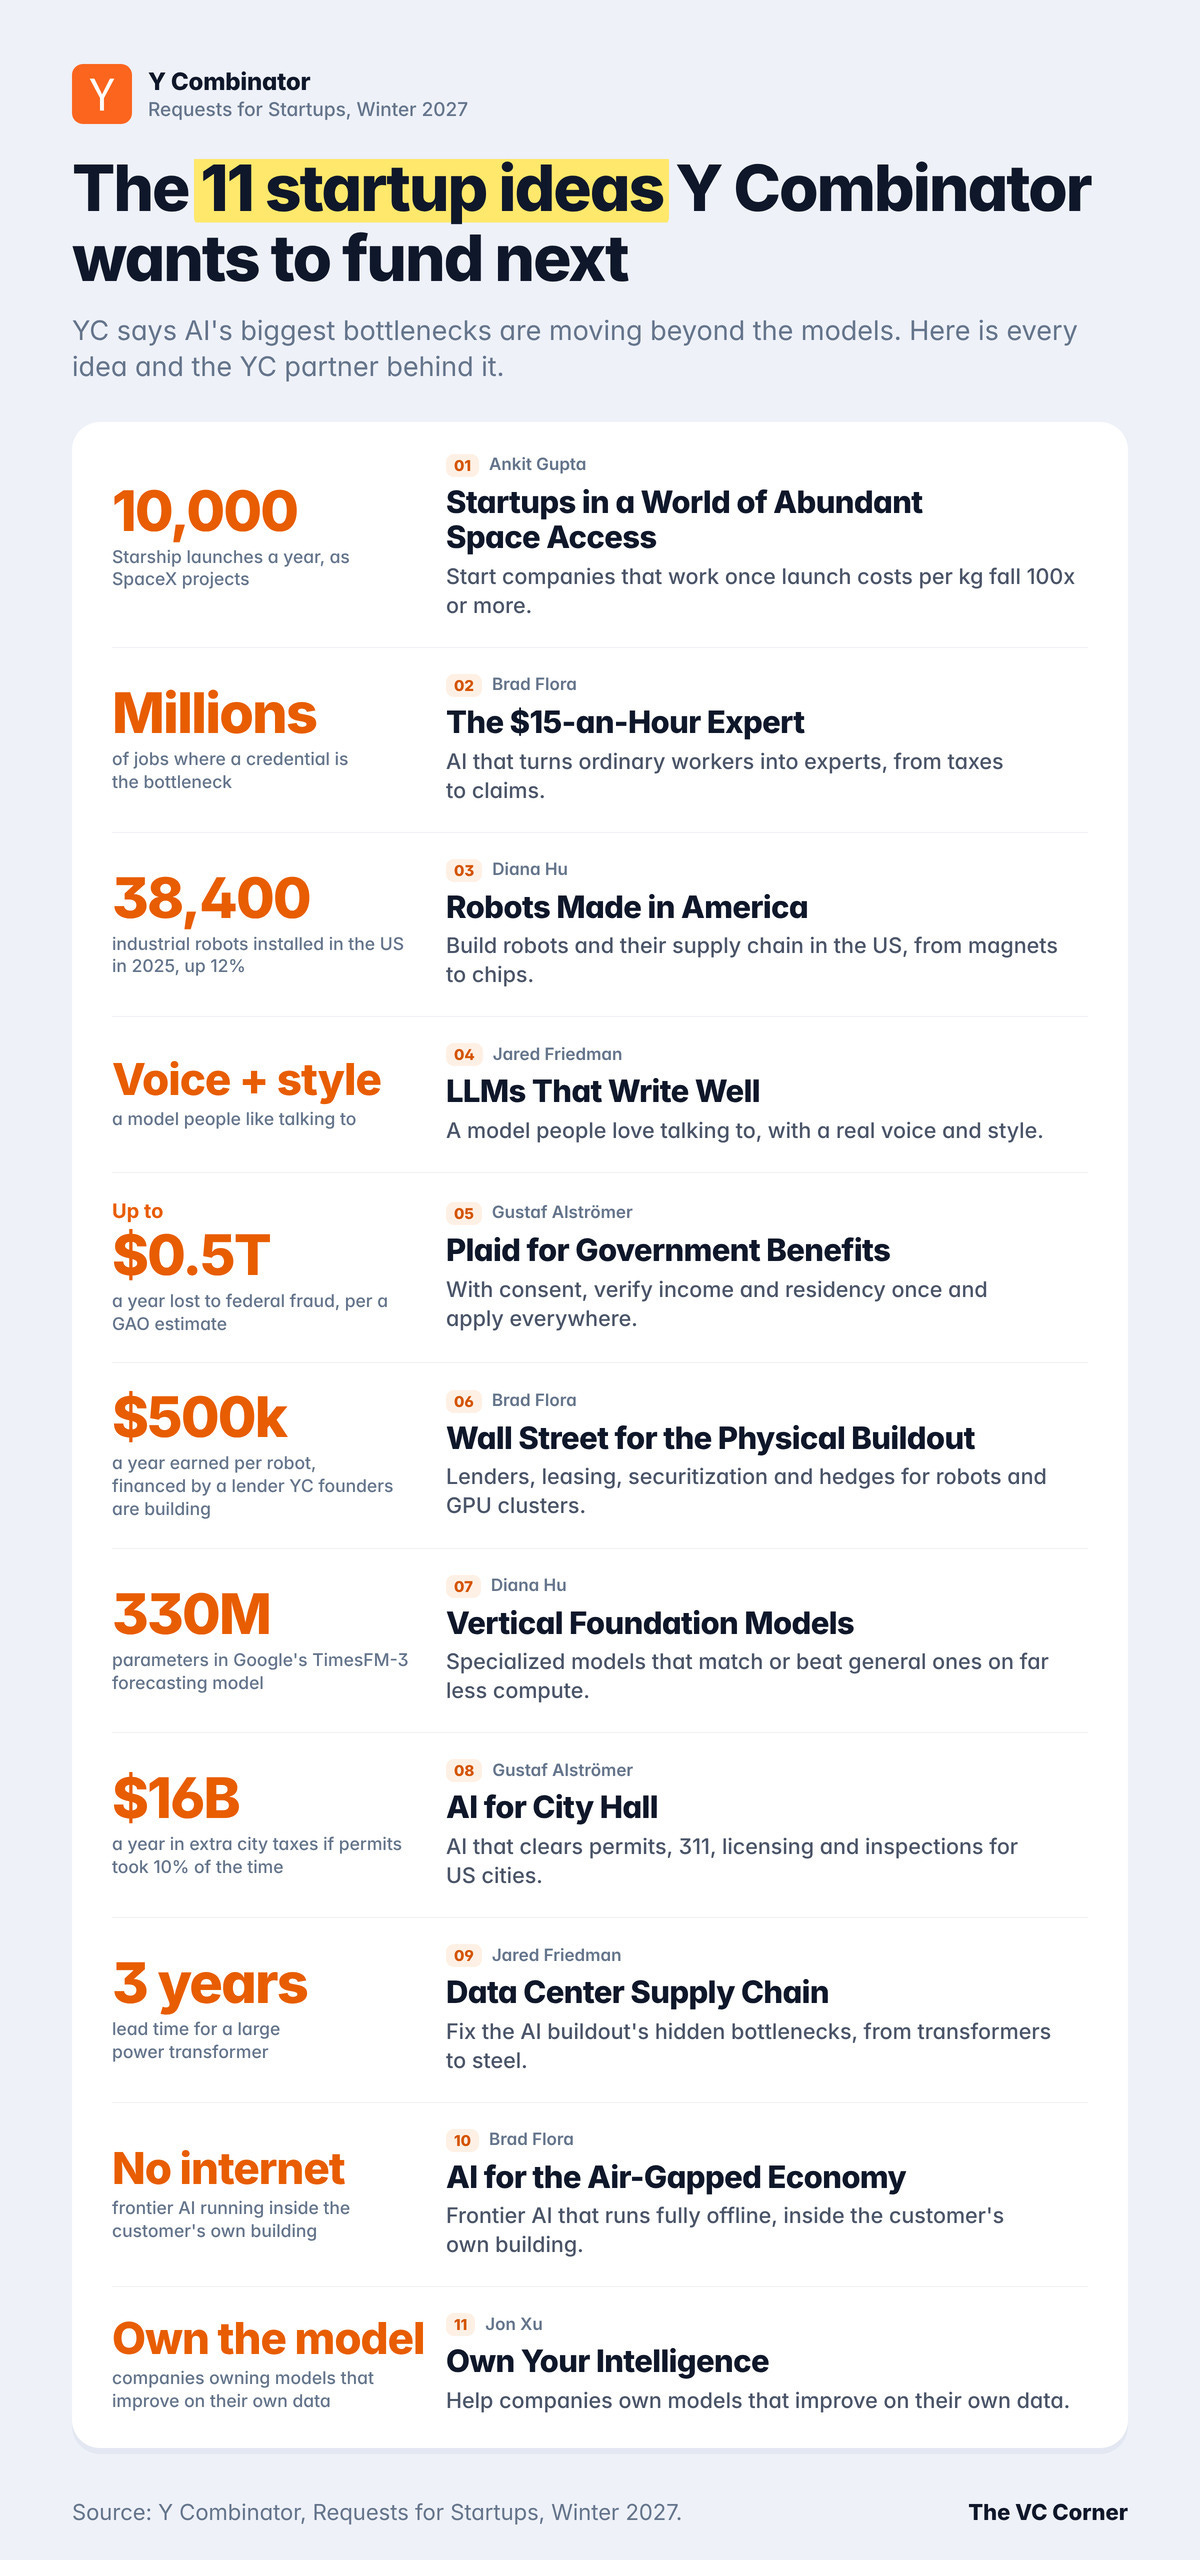
Silicon Valley Robotics Investor/Startup Database
Every month or two we share updated startup information with accredited investors. These investors write checks anywhere from angel and seed stage to $5-50 million.
- Feedback from the startups – high quality inbound interest from investors.
- Feedback from the investors – incredible depth and range of robotics startups.
Are you a startup fundraising atm? Fill out our “For Investors Eyes Only” sheet.
If you’re an accredited investor and haven’t already signed up for the spreadsheet – Sign up here for great robotics deal flow!
SVR Startup Pitch Showcase – Nov 12
We are looking for one more 8 early stage robotics startups (raised less than $5 million to date) to present your five minute pitches in front of a panel of investors on Nov 12 at the Korea/SV Physical AI Conference at Plug’n’Play.
If you enjoy Robots & Startups please restack. To receive new posts and support my work, consider becoming a free or paid subscriber.
Should robots be generalists or specialists?
Matt Mason at Matt’s Robotics Blog
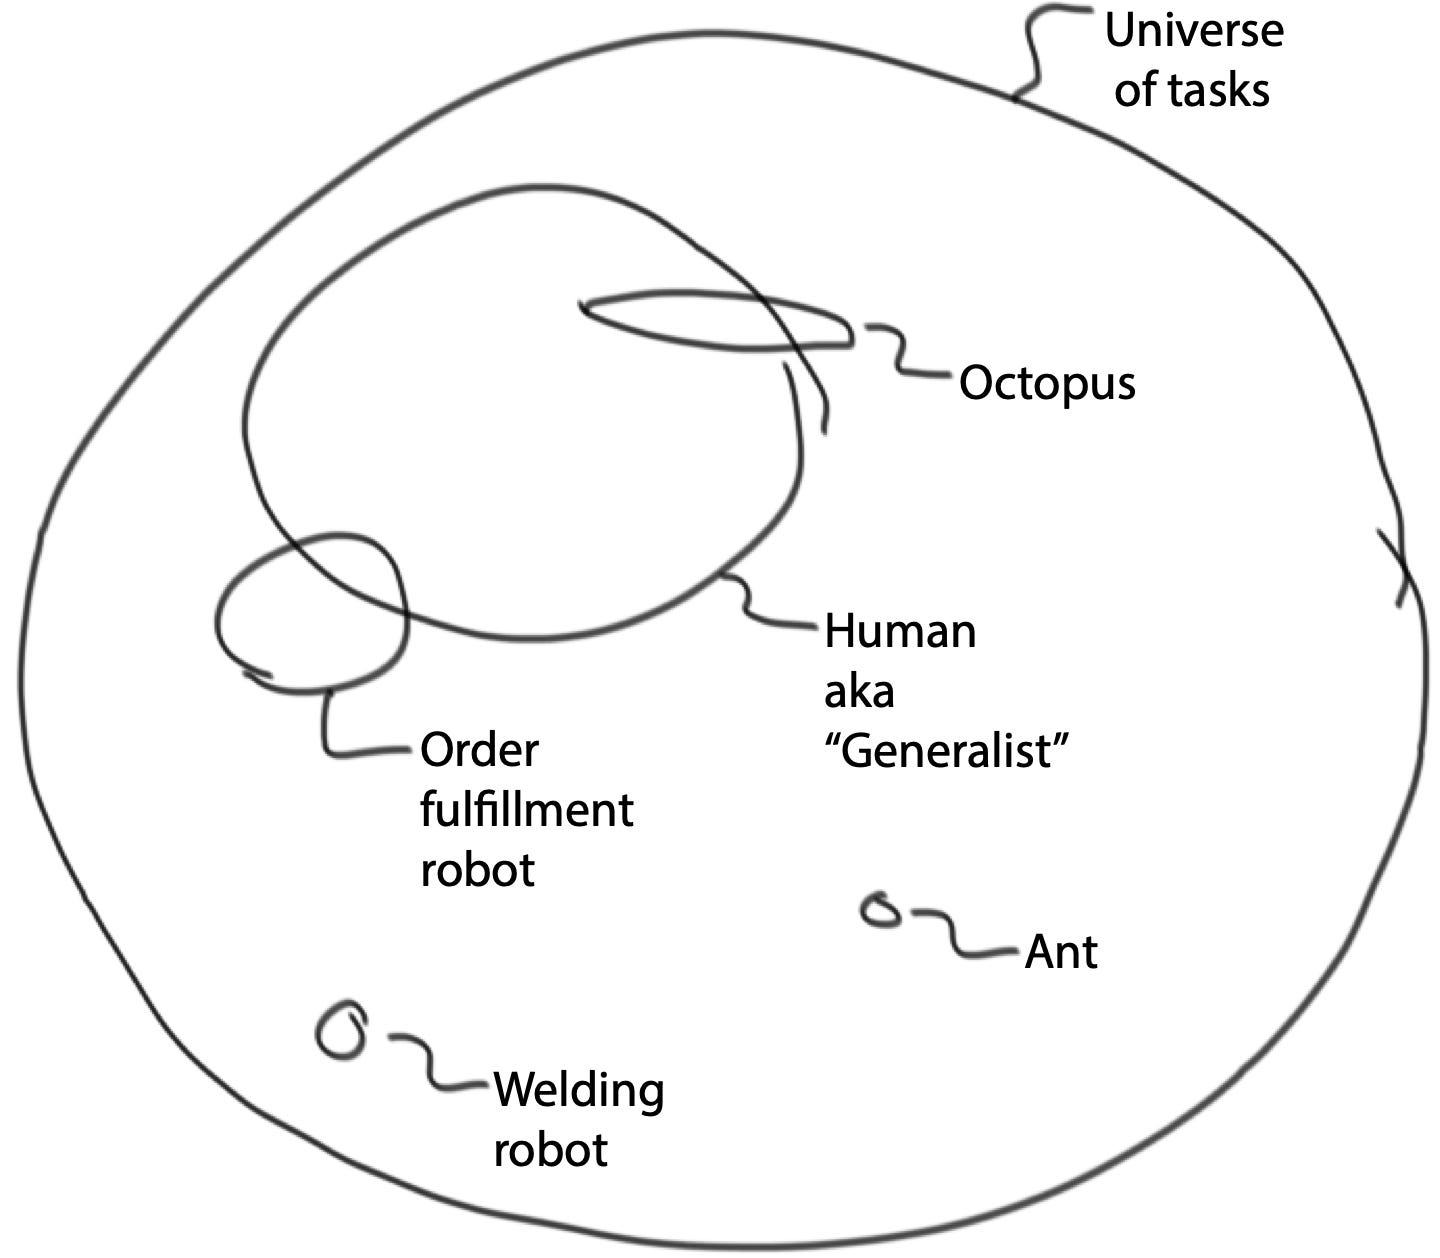
Should robots be generalists or specialists? That was the topic for a recent IROS debate. IROS (The IEEE International Conference on Intelligent Robots & Systems) is one of the biggest and best robotics conferences. The debate announcement is here. A video of the debate is coming, but I don’t know when or where it will be posted.
I was on the team arguing for specialist robots, with three minutes to state my case. This blog post is a recap of my talk.
Ken Goldberg (UC Berkeley), and Andrea Bajcsy (Carnegie Mellon) were the moderators. They framed the debate like this: “generalist” robots can do everything humans can do, whereas “specialist” robots can reliably and rapidly perform specific tasks. Generalist robots have not yet arrived, although many groups are working to develop humanoid generalists. Specialist robots are already deployed in factories and warehouses.
So, should robots be generalists or specialists? It is a complex question, touching on many issues of engineering, economics, and culture. What to say in just three minutes? I went for a broad perspective …
Read more here: https://mtmason.com/should-robots-be-generalists-or-specialists/
 What to Tell the Robot
13 days ago · 3 likes · David Watkins and Stefanie Tellex
Robotics News
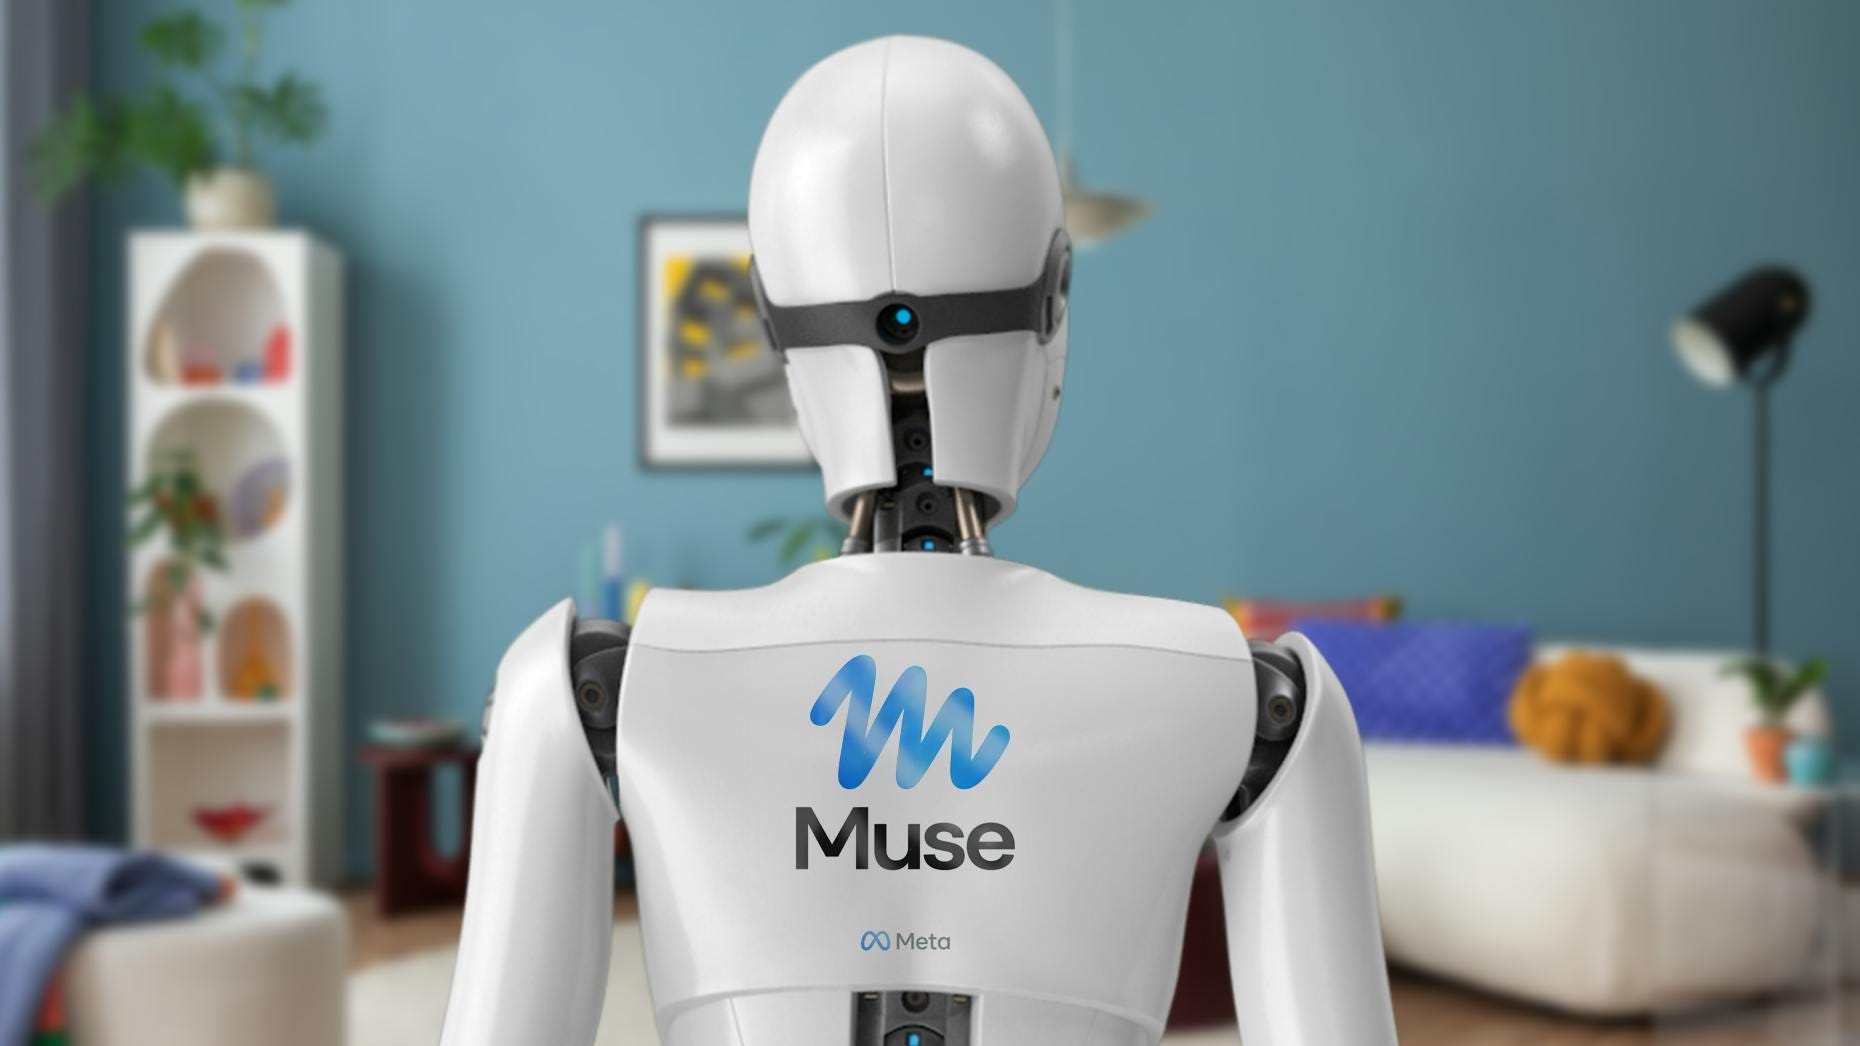
Meta Built Humanoid Prototype With Chinese Startup To Ramp Up Robotics Push
The company built a prototype called Max with China’s Fourier and is now working on a second version. Read more at The Information
Agility Robotics and Churchill Capital Corp XI Announce Expected Gross Capital Raise of Approximately $465 Million and Anticipated Closing of Business Combination – Yahoo Finance
World’s Biggest Humanoid Robot Maker Wants To Change How We Measure Robot Work – Forbes
Toyota, Waymo to test autonomous bZ4Xs in Japan in 2027, eye overseas expansion – Reuters
Bedrock Robotics digs up $600M in new funding – Construction Dive
She Just Debuted a New Device To help Braiders Work Faster – Because of Them We Can
Krafton-backed Ludo Robotics releases robot intelligence model designed around human intent – SiliconANGLE
Robotics Events
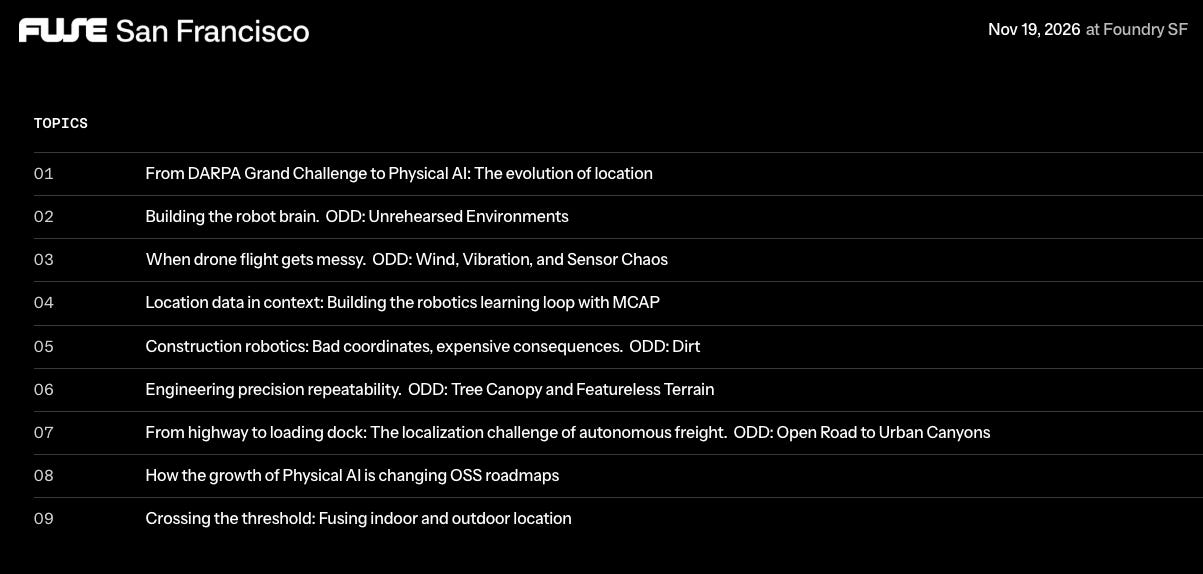
FUSE is the location technology conference for Physical AI – Nov 19
As Physical AI moves from prototypes to deployment at scale, reliable localization has emerged as a foundational layer. Designs that worked in the lab break down when exposed to real-world conditions.
Join leading robotics engineers in San Francisco to discuss the system design patterns they’ve used to successfully ship at scale. One day, one track, no product keynotes.
Learn more at fuse.pointonenav.com/sf Use SVR30% discount code
Want to host an event or reach the robotics community?
Many companies are reaching out to Silicon Valley Robotics about hosting events, outreach or hiring and we have a great community network, of people looking for work, of investors interested in deal flow and of technologists interested in learning about the latest advances.
Would you be interested in hosting the next Bots, Bevs and Devs? Or something customized specifically for your goals? Reach out here!
Upcoming Events:
Bay Area Robotics Symposium – Berkeley – Oct 30
Humanoids 2026 competition participation – SCCC – deadline Oct 31
SVR Startup Pitch Showcase (Apply) at Physical AI Conference (Attend) – Nov 12
SRI celebrates two new IEEE milestones – Computer History Museum – Nov 13
Foxglove Physical AI Industry Night – San Francisco – Nov 17
FUSE – San Francisco – Nov 19 (use SVR30% discount code or look for special offer in your SVR member email)
Bots, Bevs & Devs – tbd – Dec 2
IEEE Humanoids 2026 – SCCC – Dec 6-9
* including SVR Venture and Manufacturing Summits – Dec 7
Highlights from IEEE Humanoids 2026:
- Registration now open
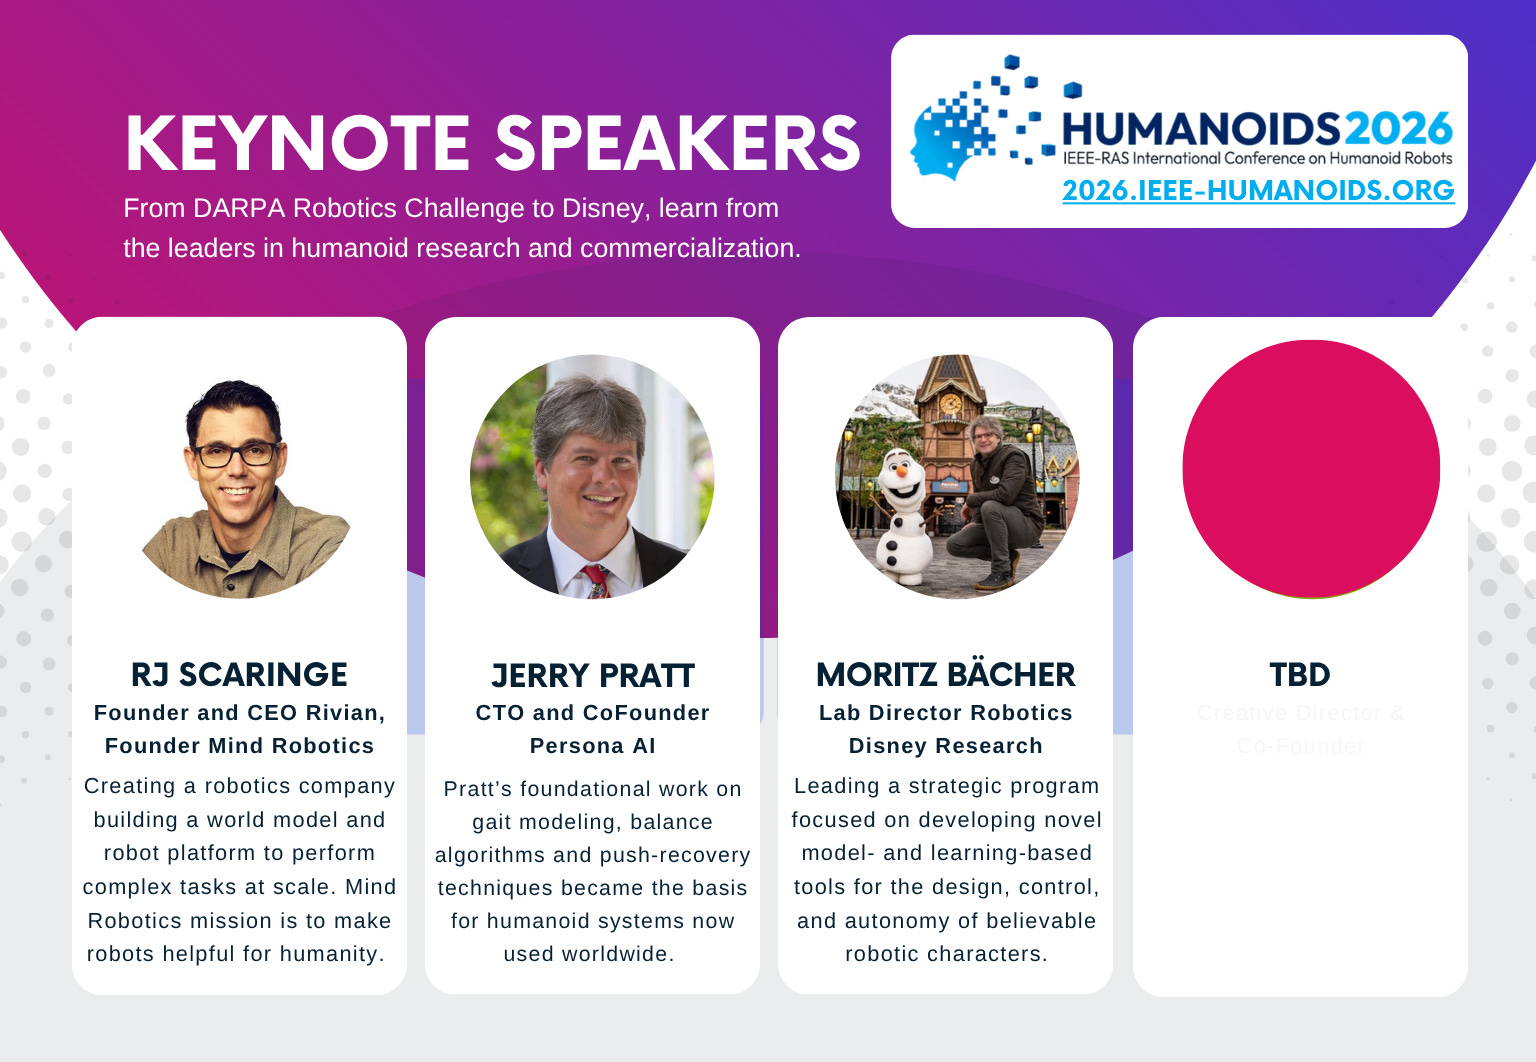
- Rong Xiong and Moritz Bächer join keynote speakers, RJ Scaringe and Jerry Pratt
- 63% increase in paper submissions
- 12 Accepted Workshops and Tutorials, plus 3 Special Summits
- NIST Humanoids 2026 Loco-Manipulation Challenge – expressions of interest are open now – deadline Oct 31. Testbed humanoids are available thanks to Partners Ultimate Bots.
Join the organizing team at Silicon Valley Robotics – bots&beer@svrobo.org